Educational Model of Eccentric Gear with Crank-Rocker Mechanism
- Arrives in 2 to 7 business days Printed in Auckland. $10 shipping, free over $75
- 14-day faulty refund If it arrives broken or misprinted, we reprint or refund it
- Secure checkout Card payments handled by Stripe
- Material
- High-Detail Resin (8K)
- Colour
- Grey
- Weight
- ~47 g
- Print time
- ~2.6 h
- Express shipping
- $20
More information
My Educational Mechanical Examples Series
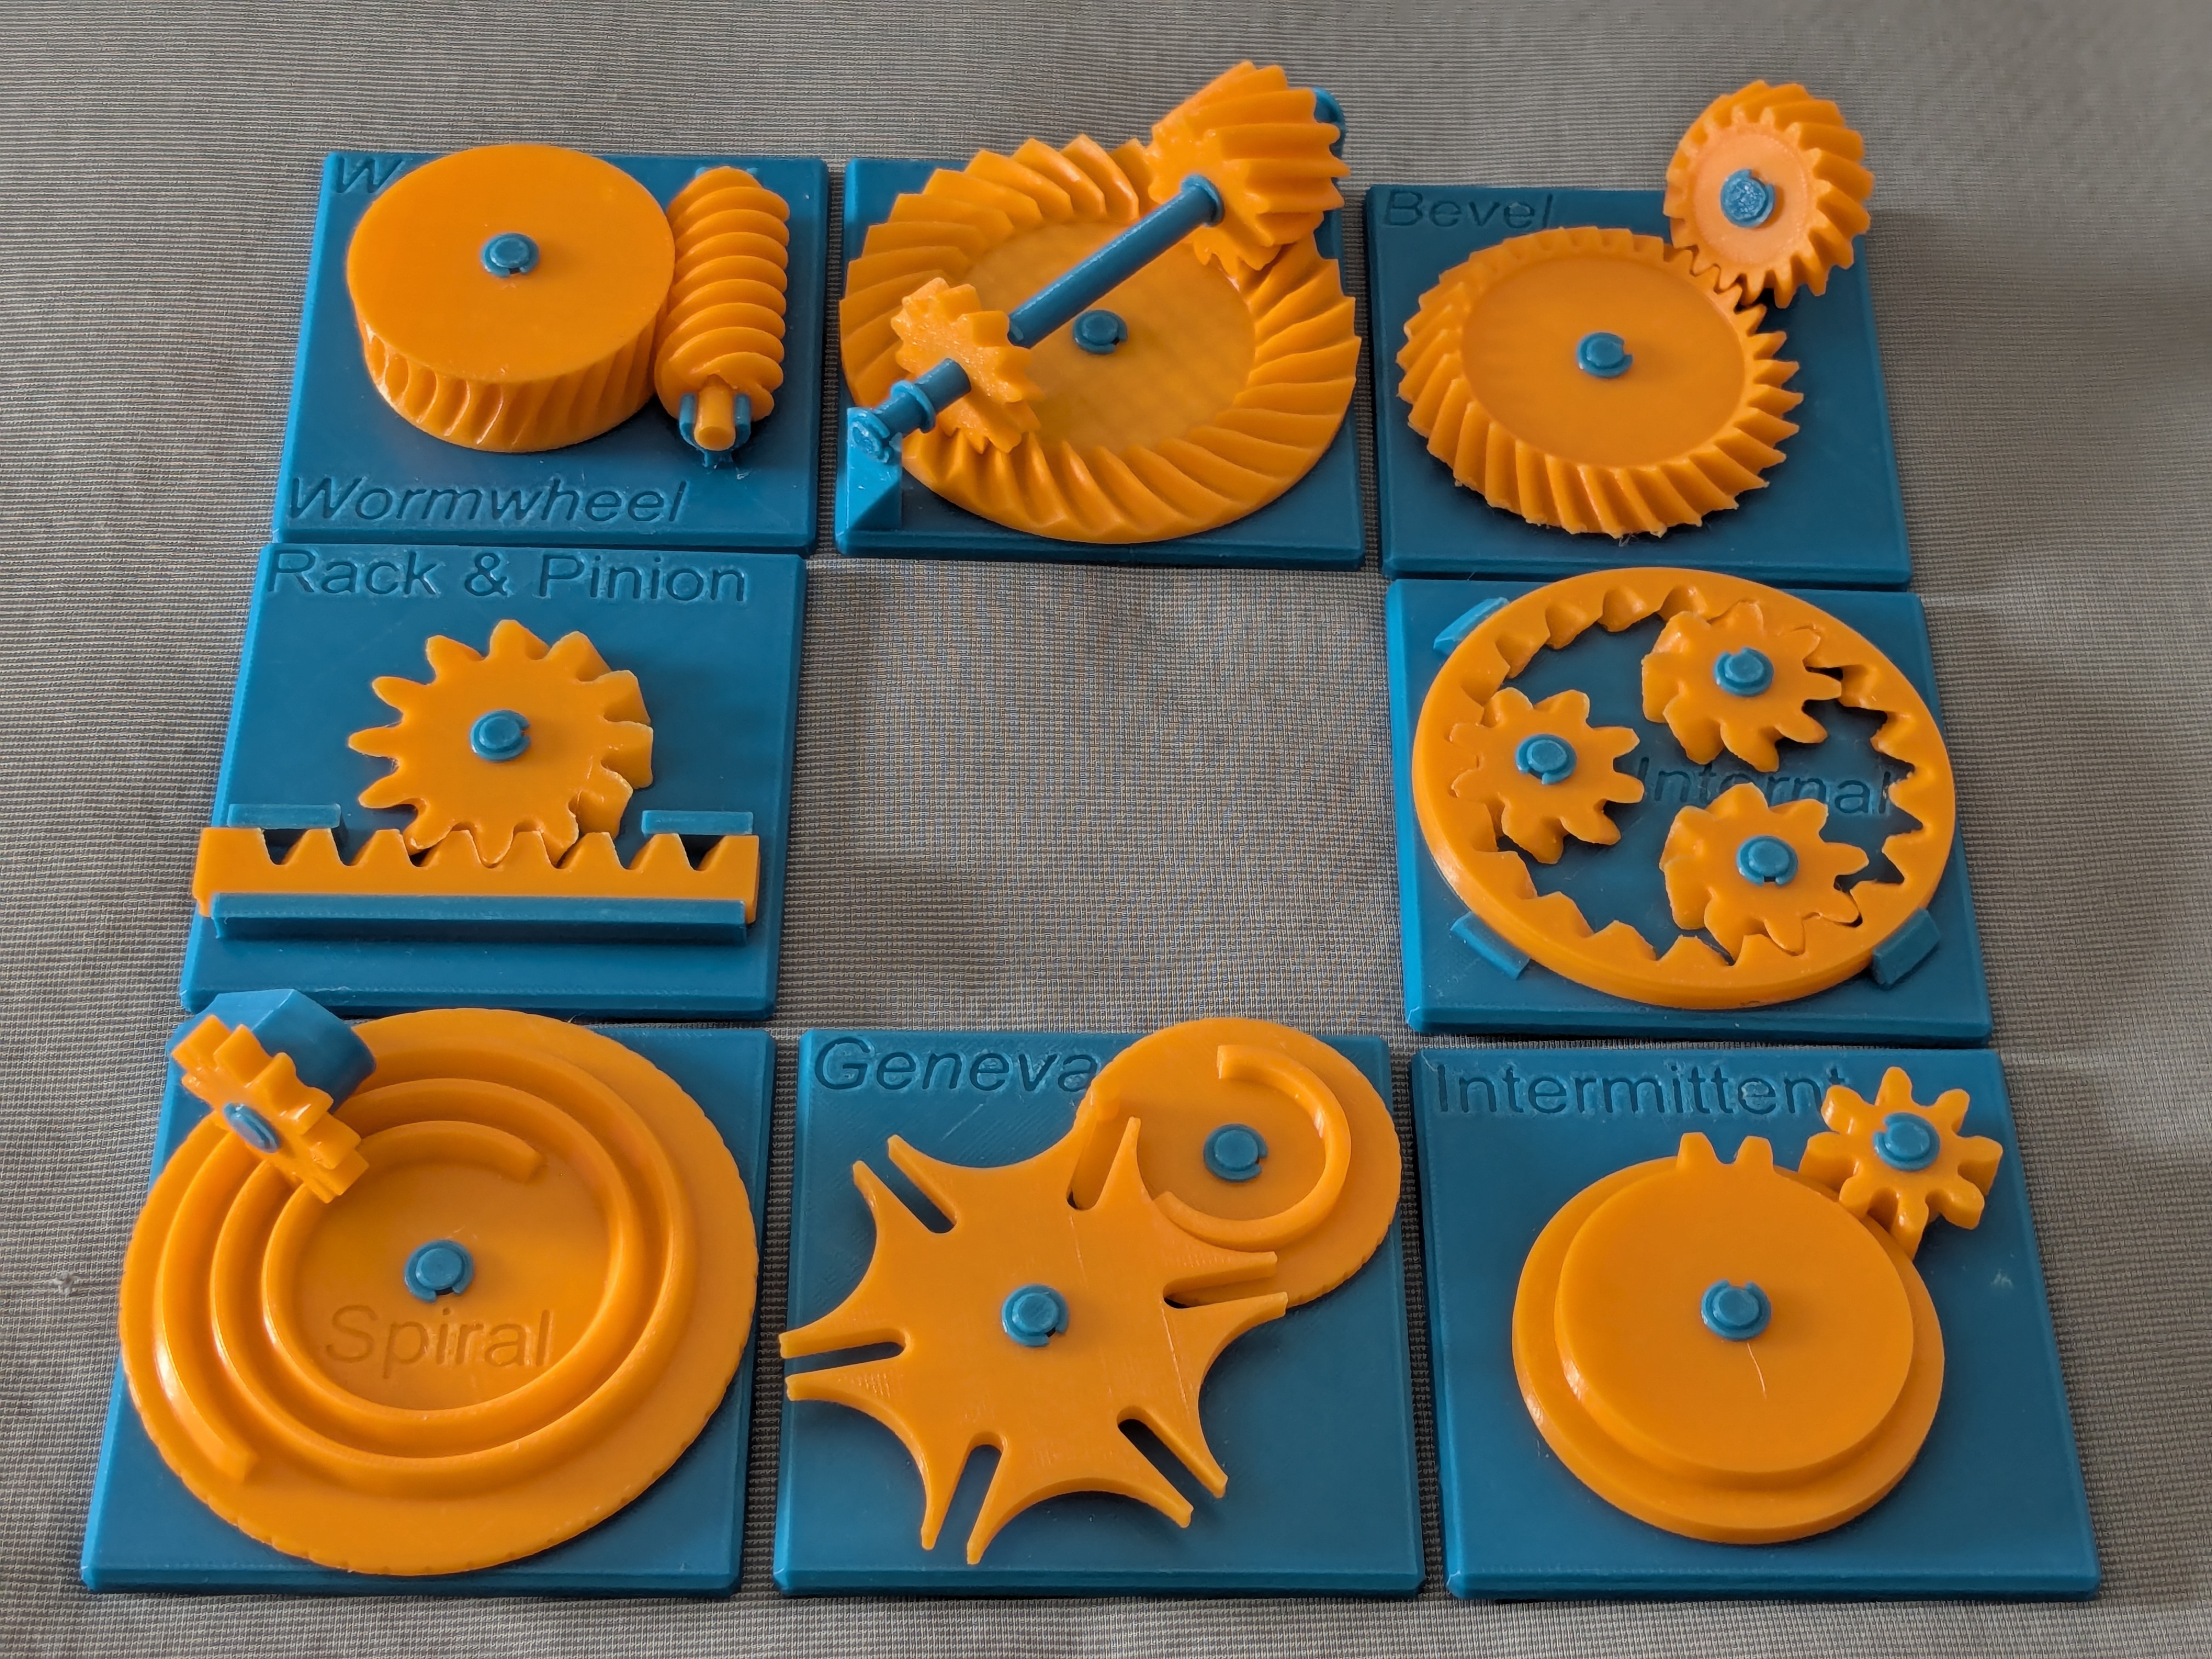
This model is one of my educational mechanical mechanism examples on 80mm x 80mm base plates. You can find all models of the series in this collection => [Mechanical Mechanism Examples]
This mode
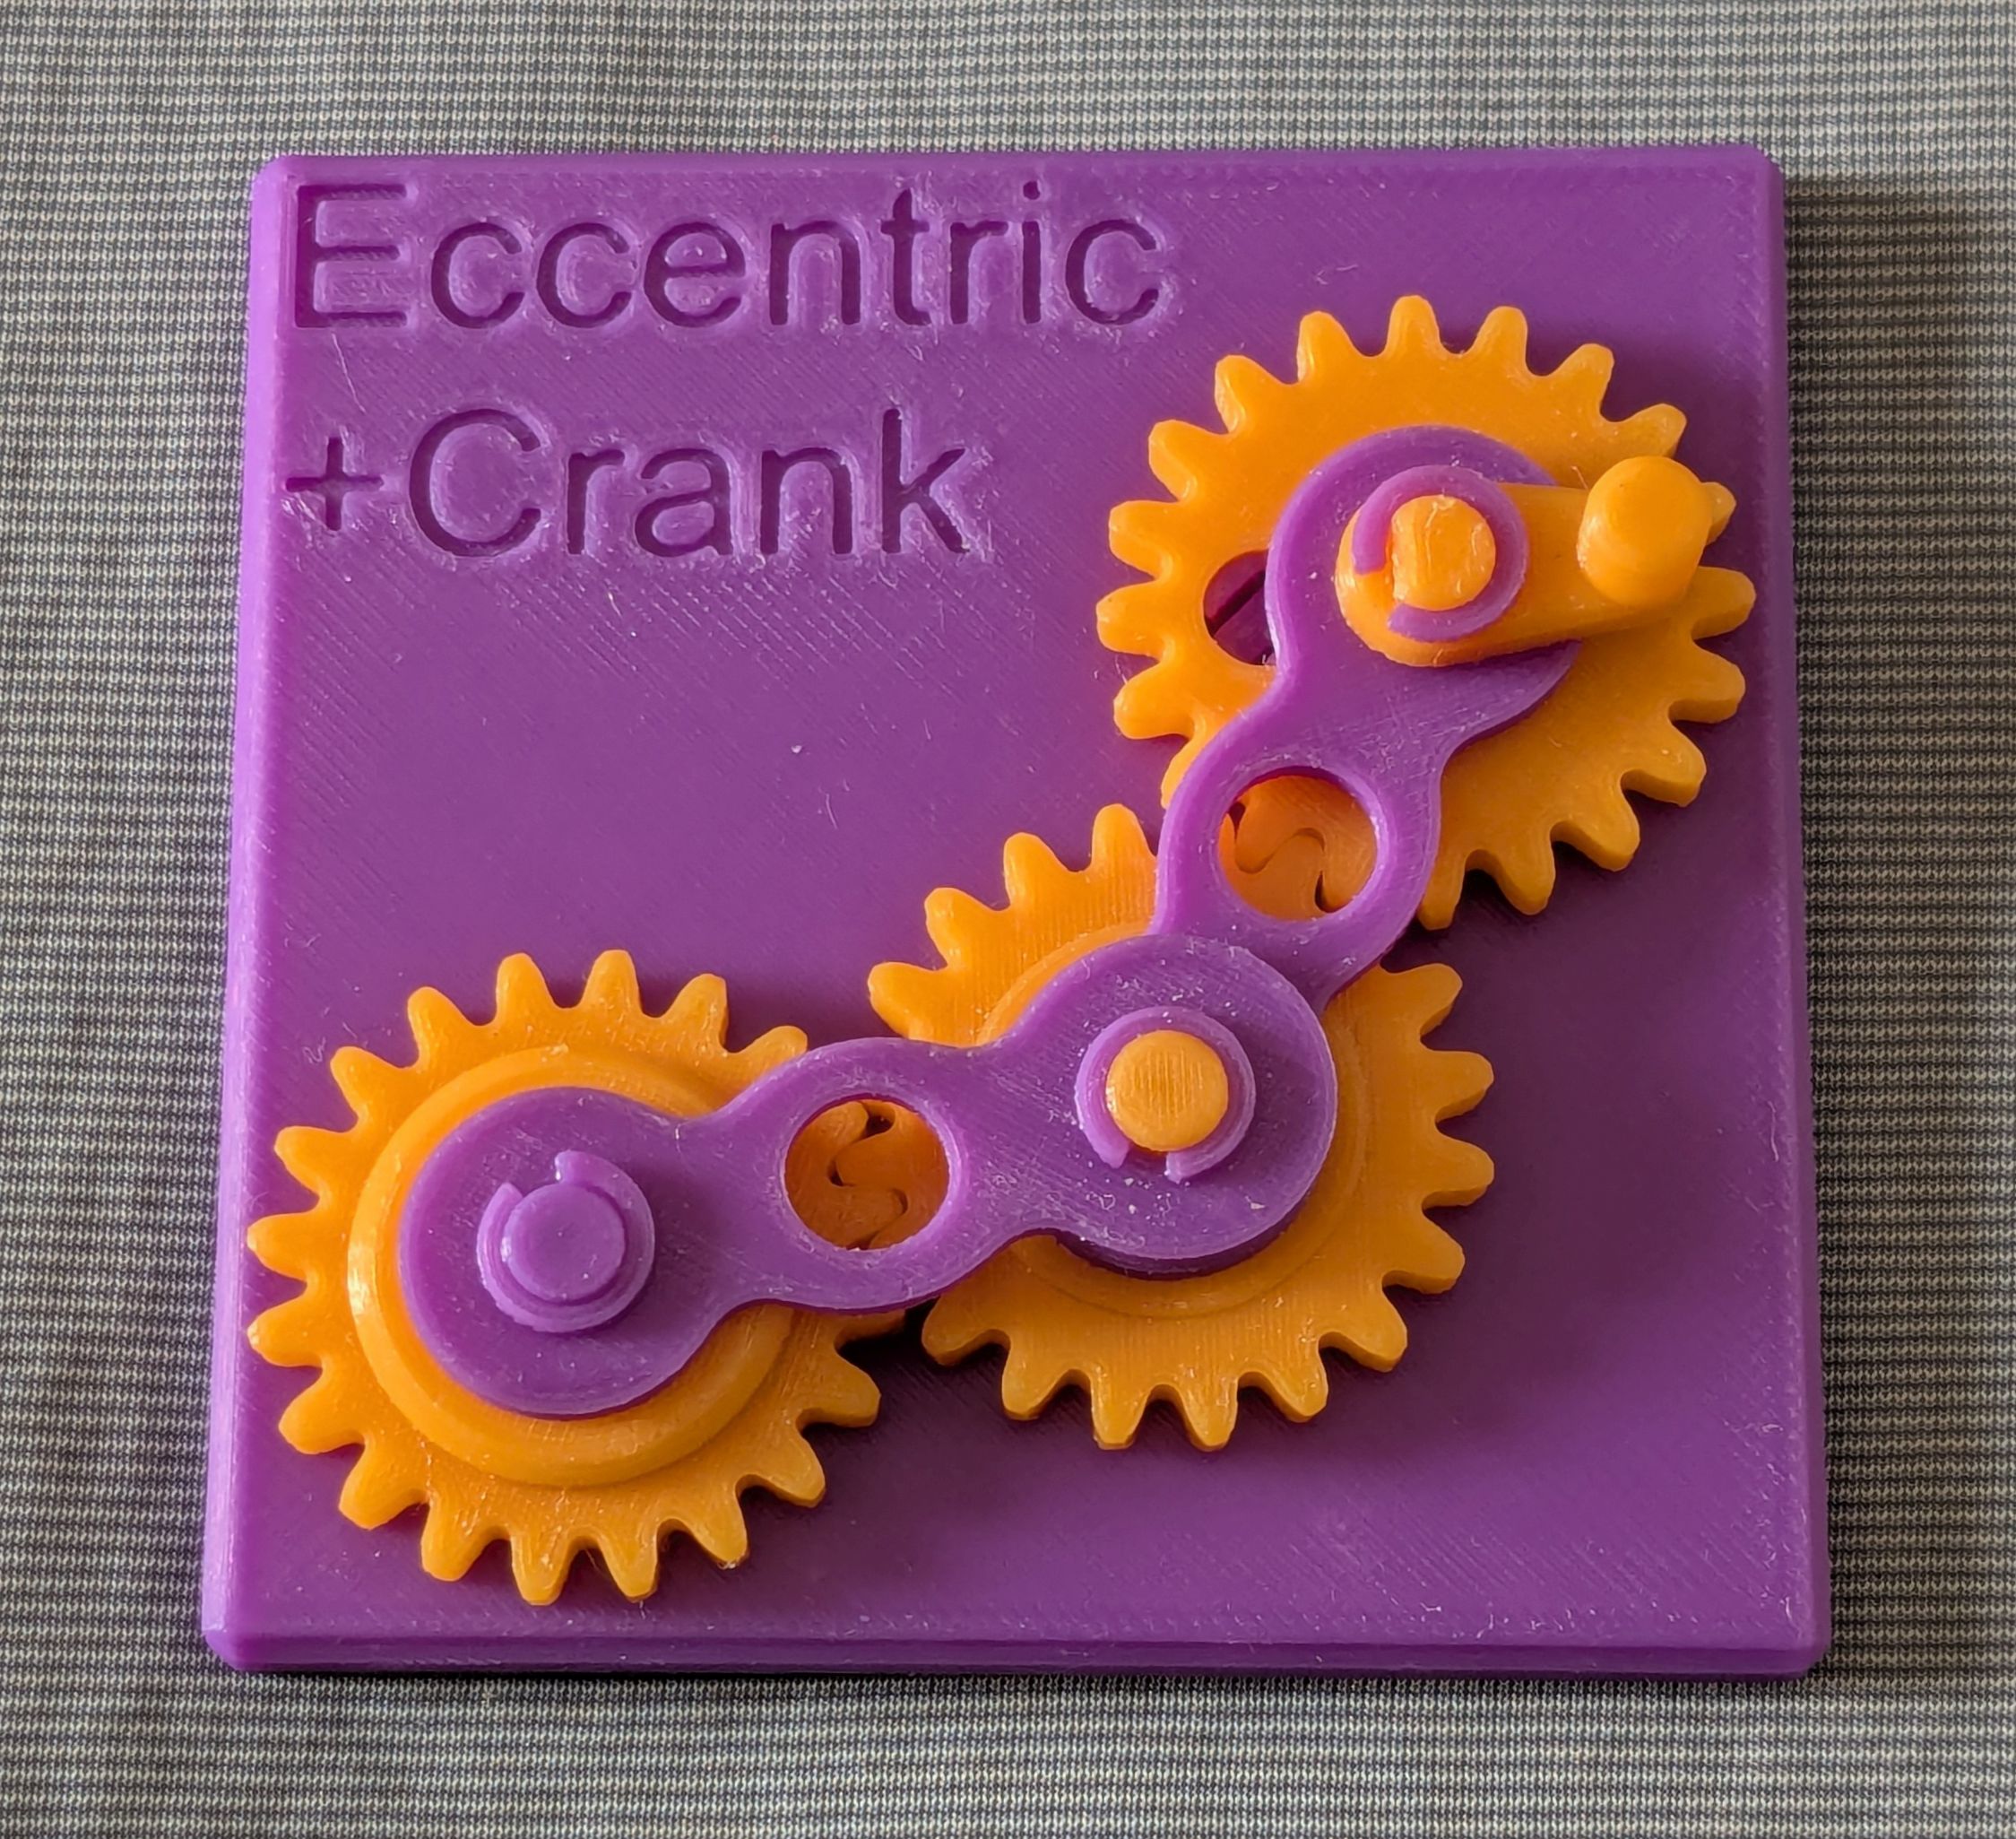
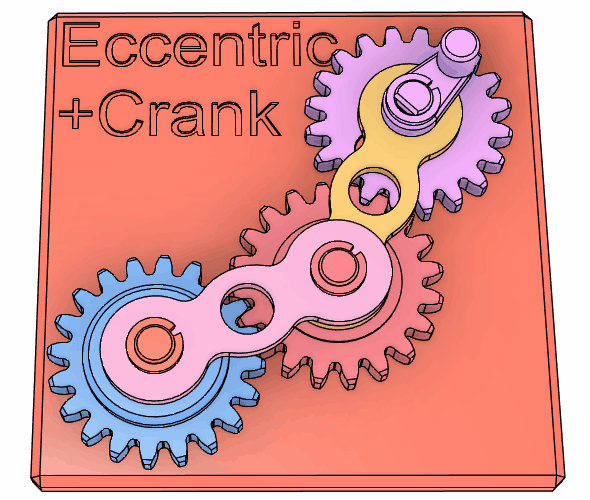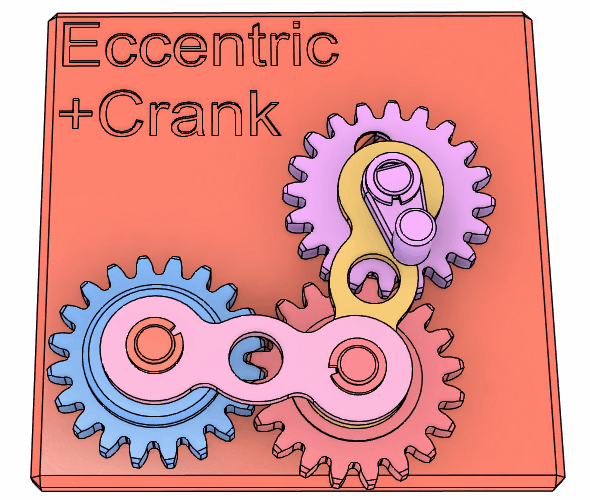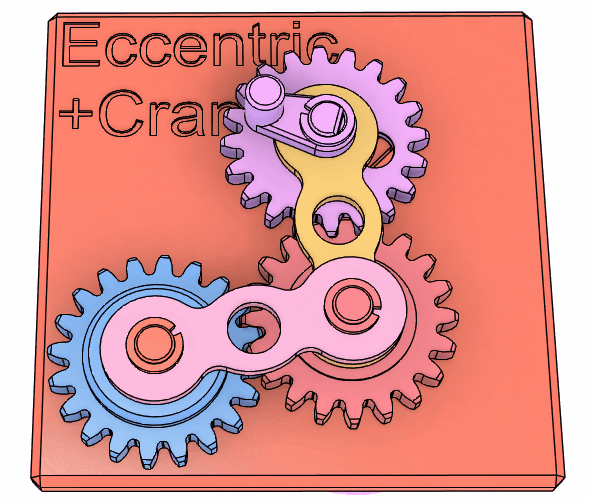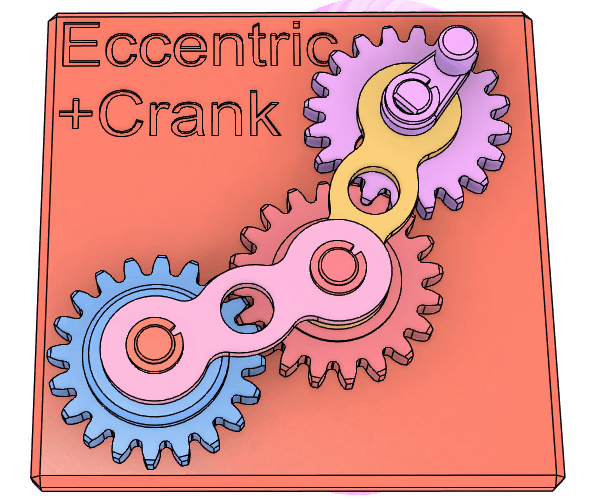
This model features a variable-speed gear mechanism composed of an eccentric spur gear and two ordinary spur gears. The axis of the middle gear is supported by a pair of linkages, which together form a four-bar crank-rocker mechanism. This clever structure allows the three gears to stay meshed even though one of them rotates eccentrically.
Brief description
The upper-right spur gear with the handle serves as the input. Its rotation axis is intentionally offset, giving it an eccentric center. Because of this eccentricity, the input gear cannot mesh with another gear whose axis is fixed. Instead, the axis of the intermediate gear is allowed to move.
A linkage keeps the center-to-center distance between the input gear and the intermediate gear constant, causing the intermediate gear to follow the eccentric motion of the input gear to maintain meshing.
The lower-left spur gear is the output, and its axis is fixed to the base plate. A second link keeps the center-to-center distance between the intermediate gear and the output gear constant. With these two linkages working together, all three gears remain continuously meshed even though the input gear rotates on an eccentric axis.
This assembly functions as a variable-speed gear mechanism: the output gear does not rotate at a constant speed even when the input gear is turned steadily. You can observe that the output gear almost pauses when the handle of the input gear is about the upward position.
Finally, note that the eccentric input gear, the two connecting links, and the base plate—which anchors two axes— together form a four-bar crank–rocker mechanism. In this mechanism, the eccentric input gear acts as the crank, driving the swinging motion of the links. This swinging motion is what produces the non-uniform rotation seen at the output.
Reference
• https://karakurist.jp/?p=259
Case
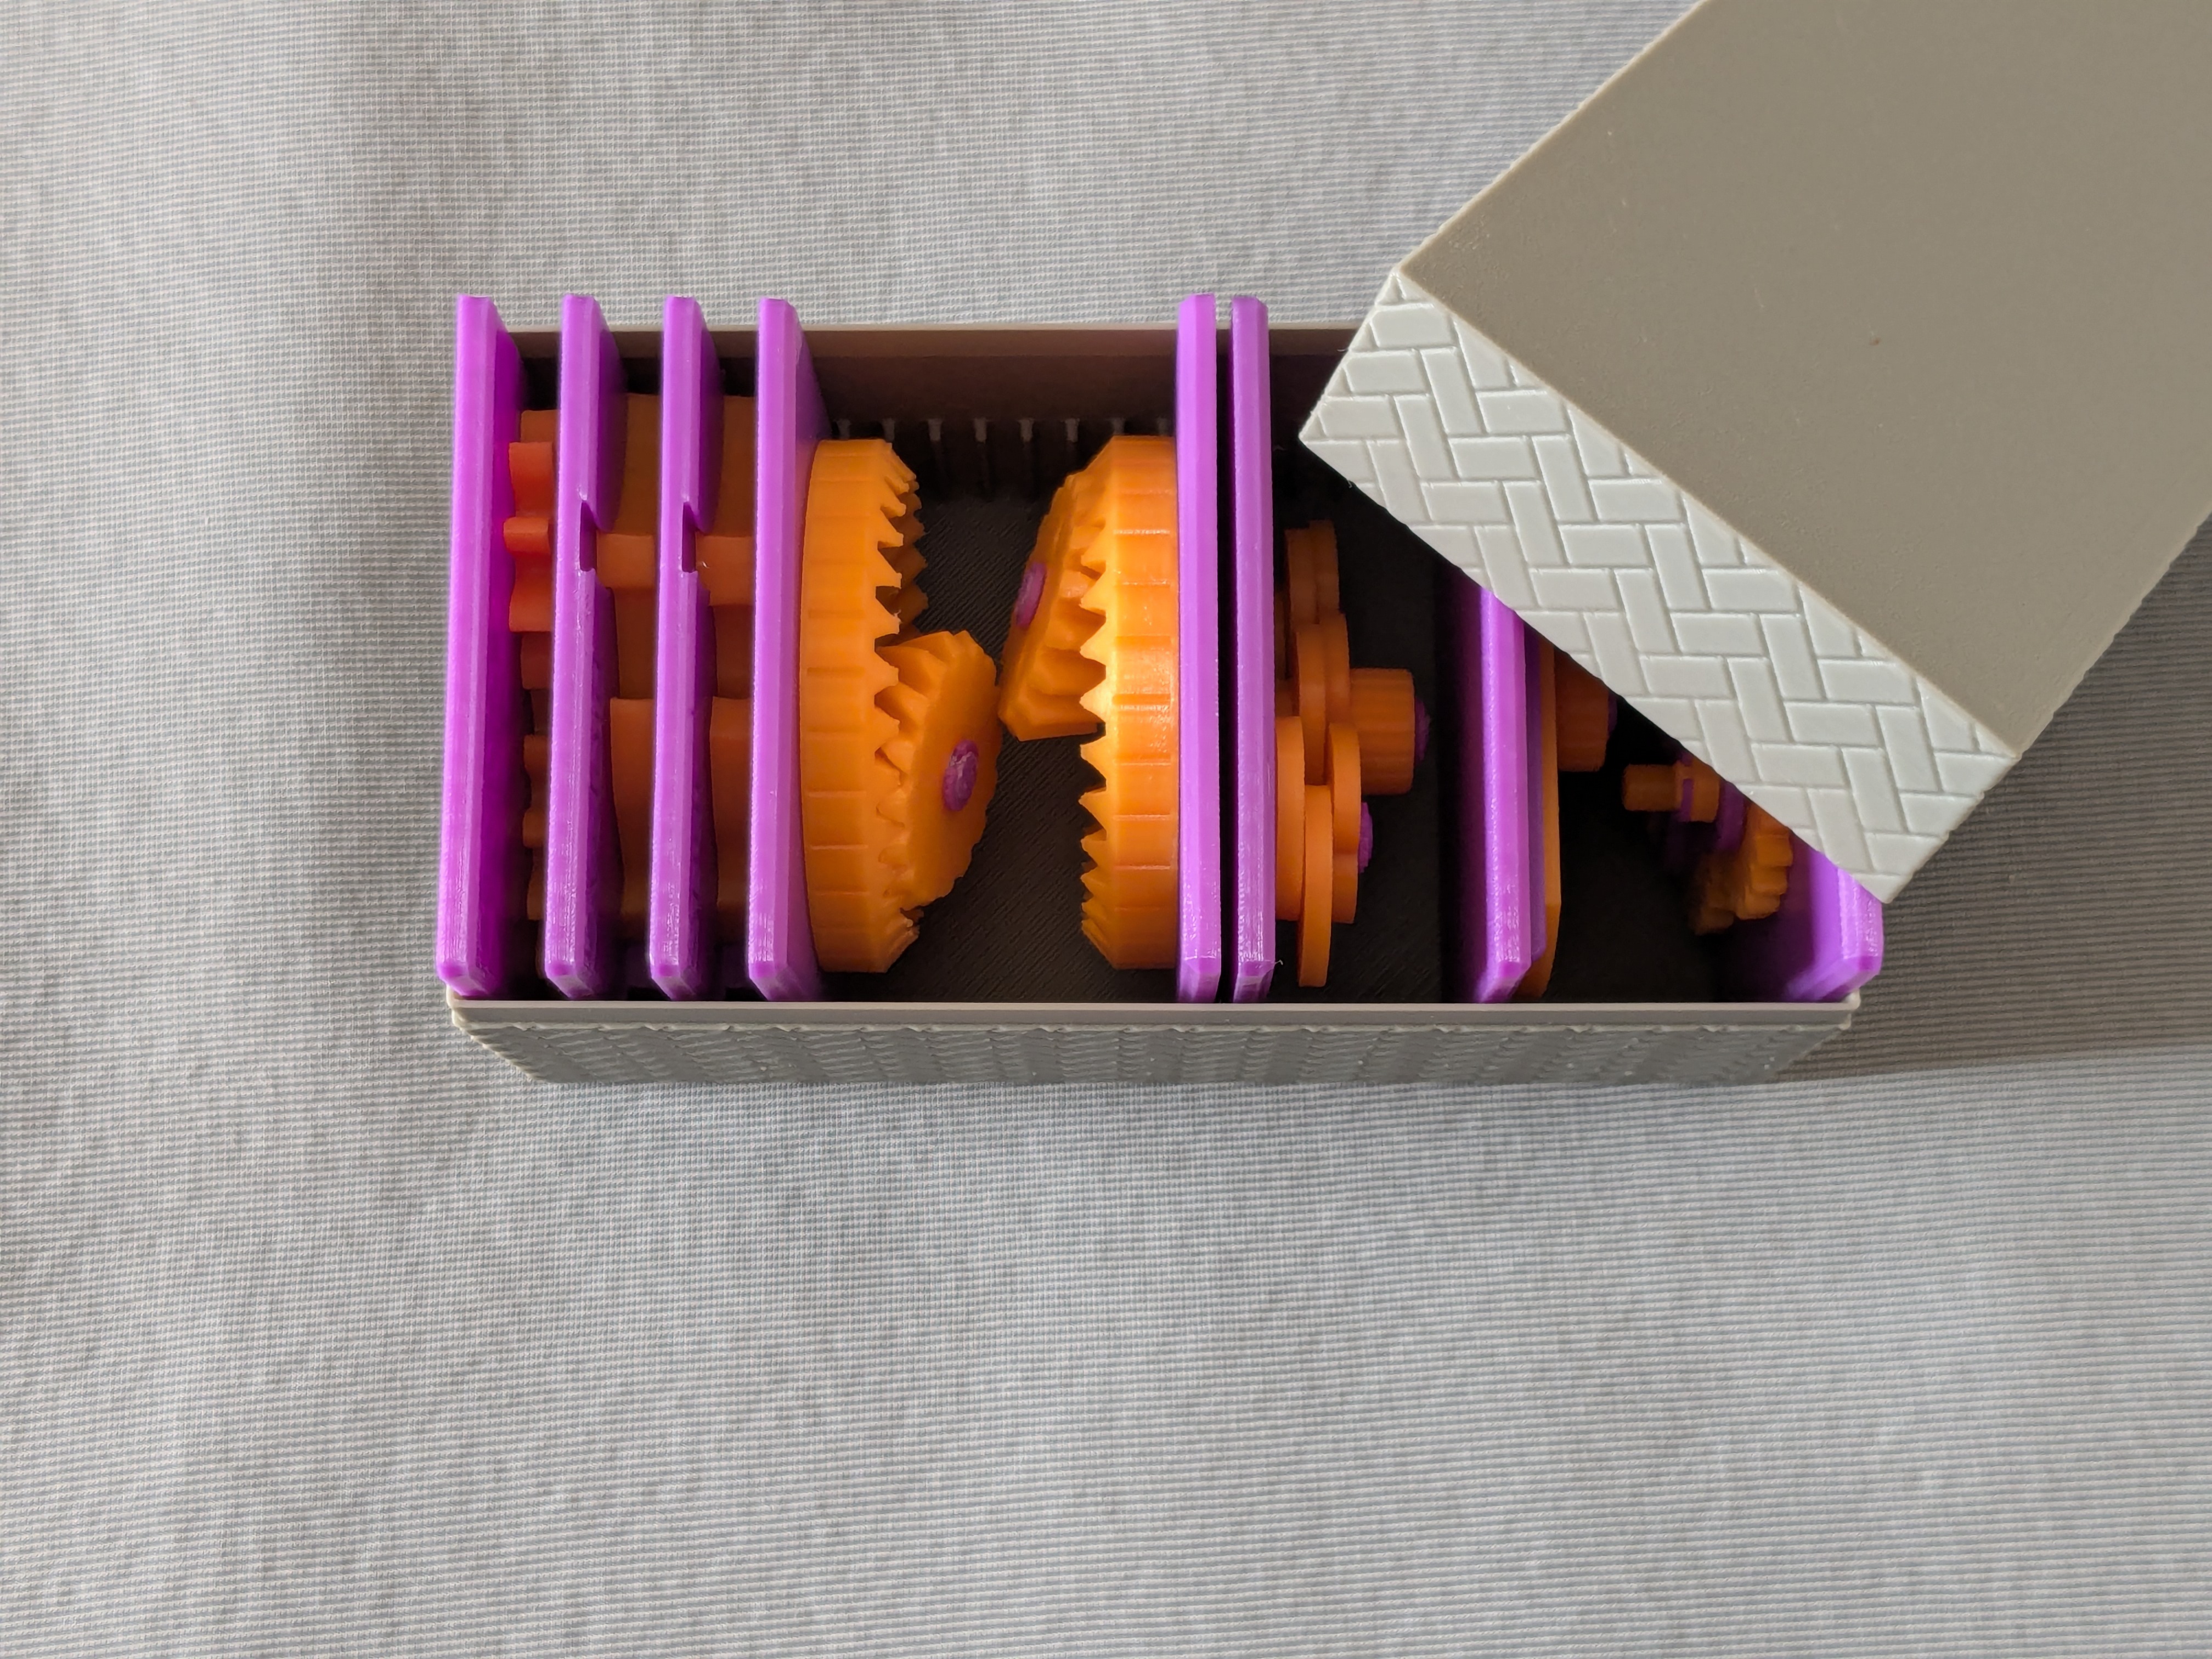
These models are compatible with the case included in my first set.
Printing
• Use the models named ???-printable.stl for printing. The models named ???-assembled.stl are provided just to show how they should be assembled.
• Use well-dried PETG to have better dimensional accuracy. • Use 0.1 mm or 0.08 mm layer height to have smoother surfaces. • Use slow printing speed for overhangs. • Select “Random” seam position to have smoother rotation. Randomly distributed seam should be easily worn out after some wearing.
Sanding and Filing
Sometimes, the gears suffer from the stringing effect and/or elephant foot effect, resulting in a too tight fit to the shafts (they are designed with a 0.15 mm radial clearance).
If you see rough surface on the shafts due to stringing, sand off the roughness with a small piece of sand paper.
If you feel the gears do not rotate smoothly due to an elephant effect, widen the hole slightly by using a thin round bar file.
Without those issues, the gears should rotate very smoothly with minimal friction.
Assembly
No glue is needed.
Everything is assembled by snap fit and retaining rings.
If you use moisturised filament, the snap tab of the eccentric shaft may be printed fragile. Be careful not to break it.
Other educational models
You may also be interested in the models in my educational mechanical mechanism examples.
Find them in this collection: https://www.printables.com/@osamutake_3341417/collections/2728214
Acknowledgement
I got into gears thanks to K.$uzuki's amazing articles and YouTube videos. Many of the mechanisms shown here came from the introductions on his website. He also makes excellent gear models himself. This series wouldn’t have existed without his inspiration.
I learned a lot about technical detail of designing gear tooth profiles from Haguruma-No-Hanashi website. I’m truly grateful for that.Happy printing!
Design and description by osamutake , licensed CC-BY.
Frequently asked
How long does shipping take?
Educational Model of Eccentric Gear with Crank-Rocker Mechanism is printed to order. Lead time is typically 1-3 business days plus 1-4 days NZ shipping. Standard NZ shipping is $10, free over $75.
What material is this printed in?
By default this is printed in High-Detail Resin (8K) at 0.025 mm layer height on an MSLA resin printer. Custom material and colour swaps are available, just leave a note at checkout.
Can I get this in a different colour?
Yes. Every product can be printed in any of the resin colours we stock, or hand-painted on request. Leave a note at checkout or email [email protected].
Do you ship outside of New Zealand?
Currently New Zealand only. Australian shipping is coming.
Who designed this?
Designed by an independent sculptor and licensed for commercial printing. The original is linked on this page.