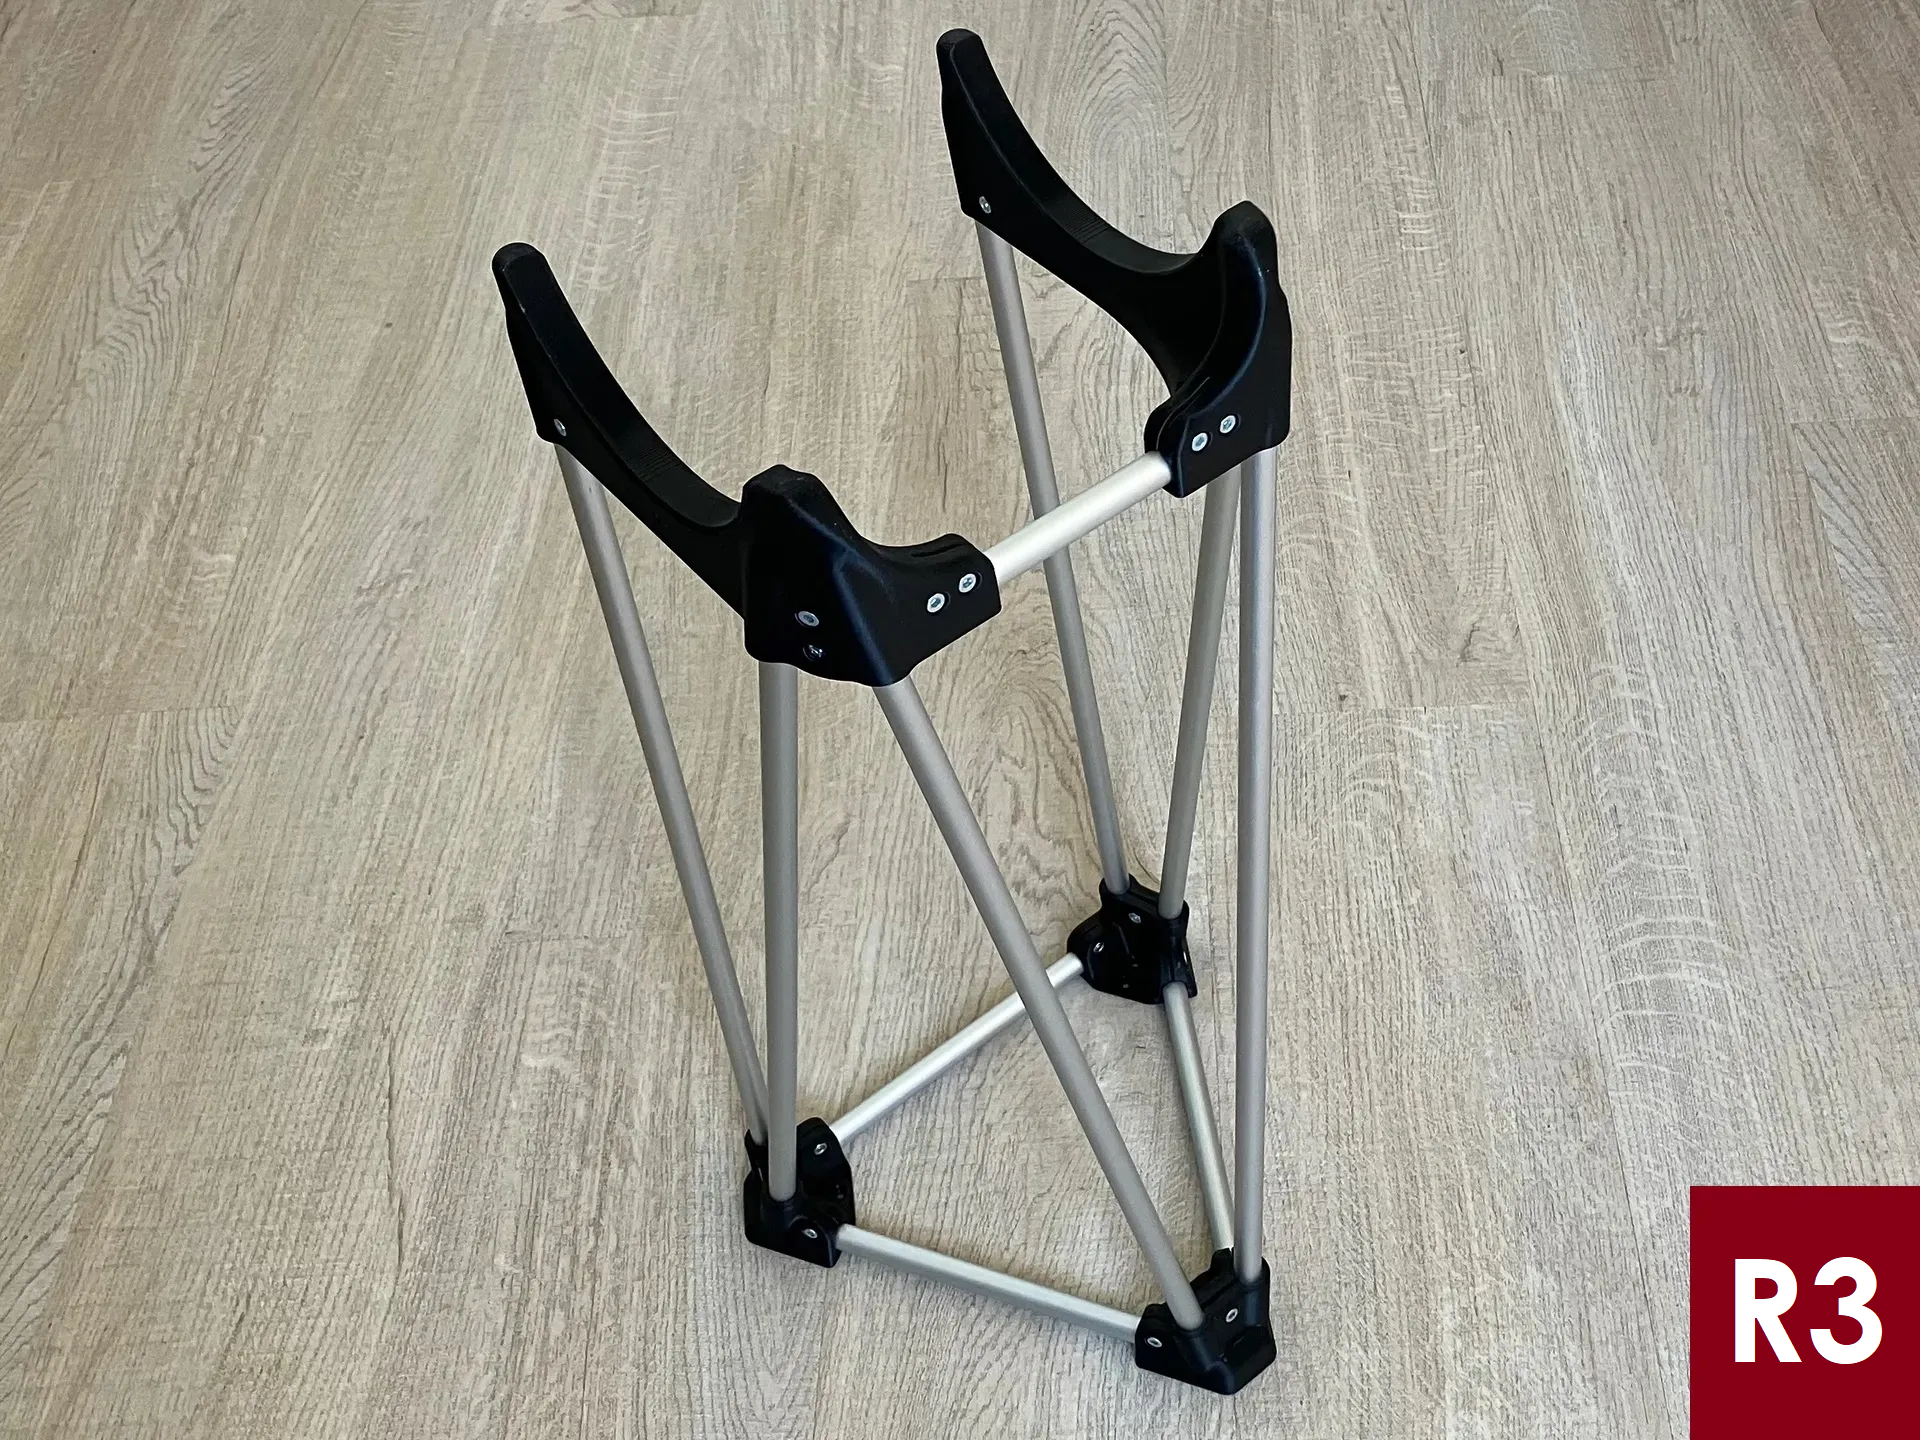
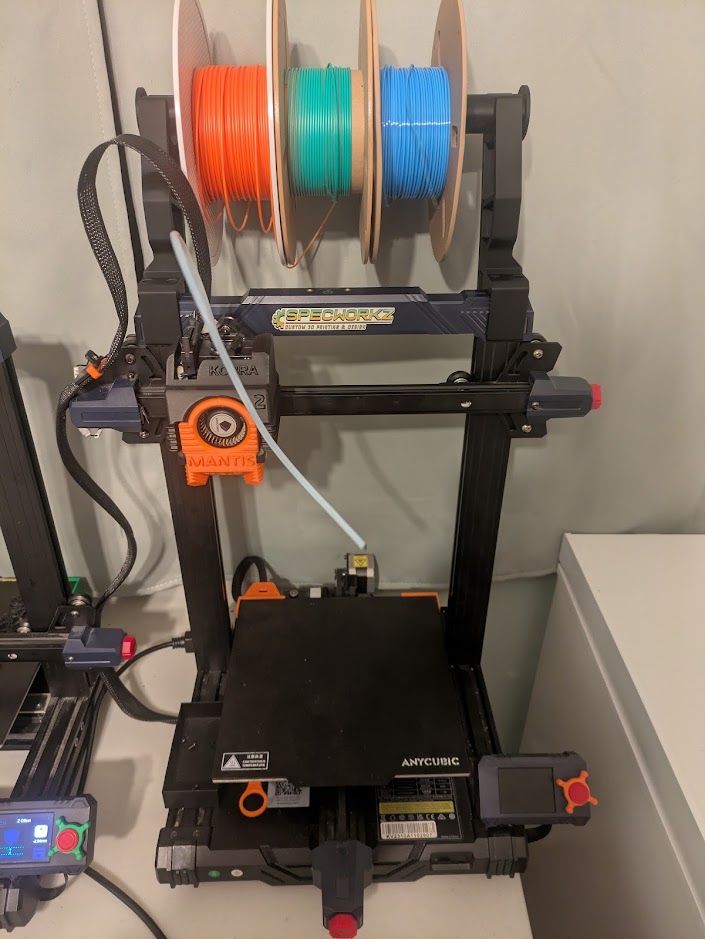
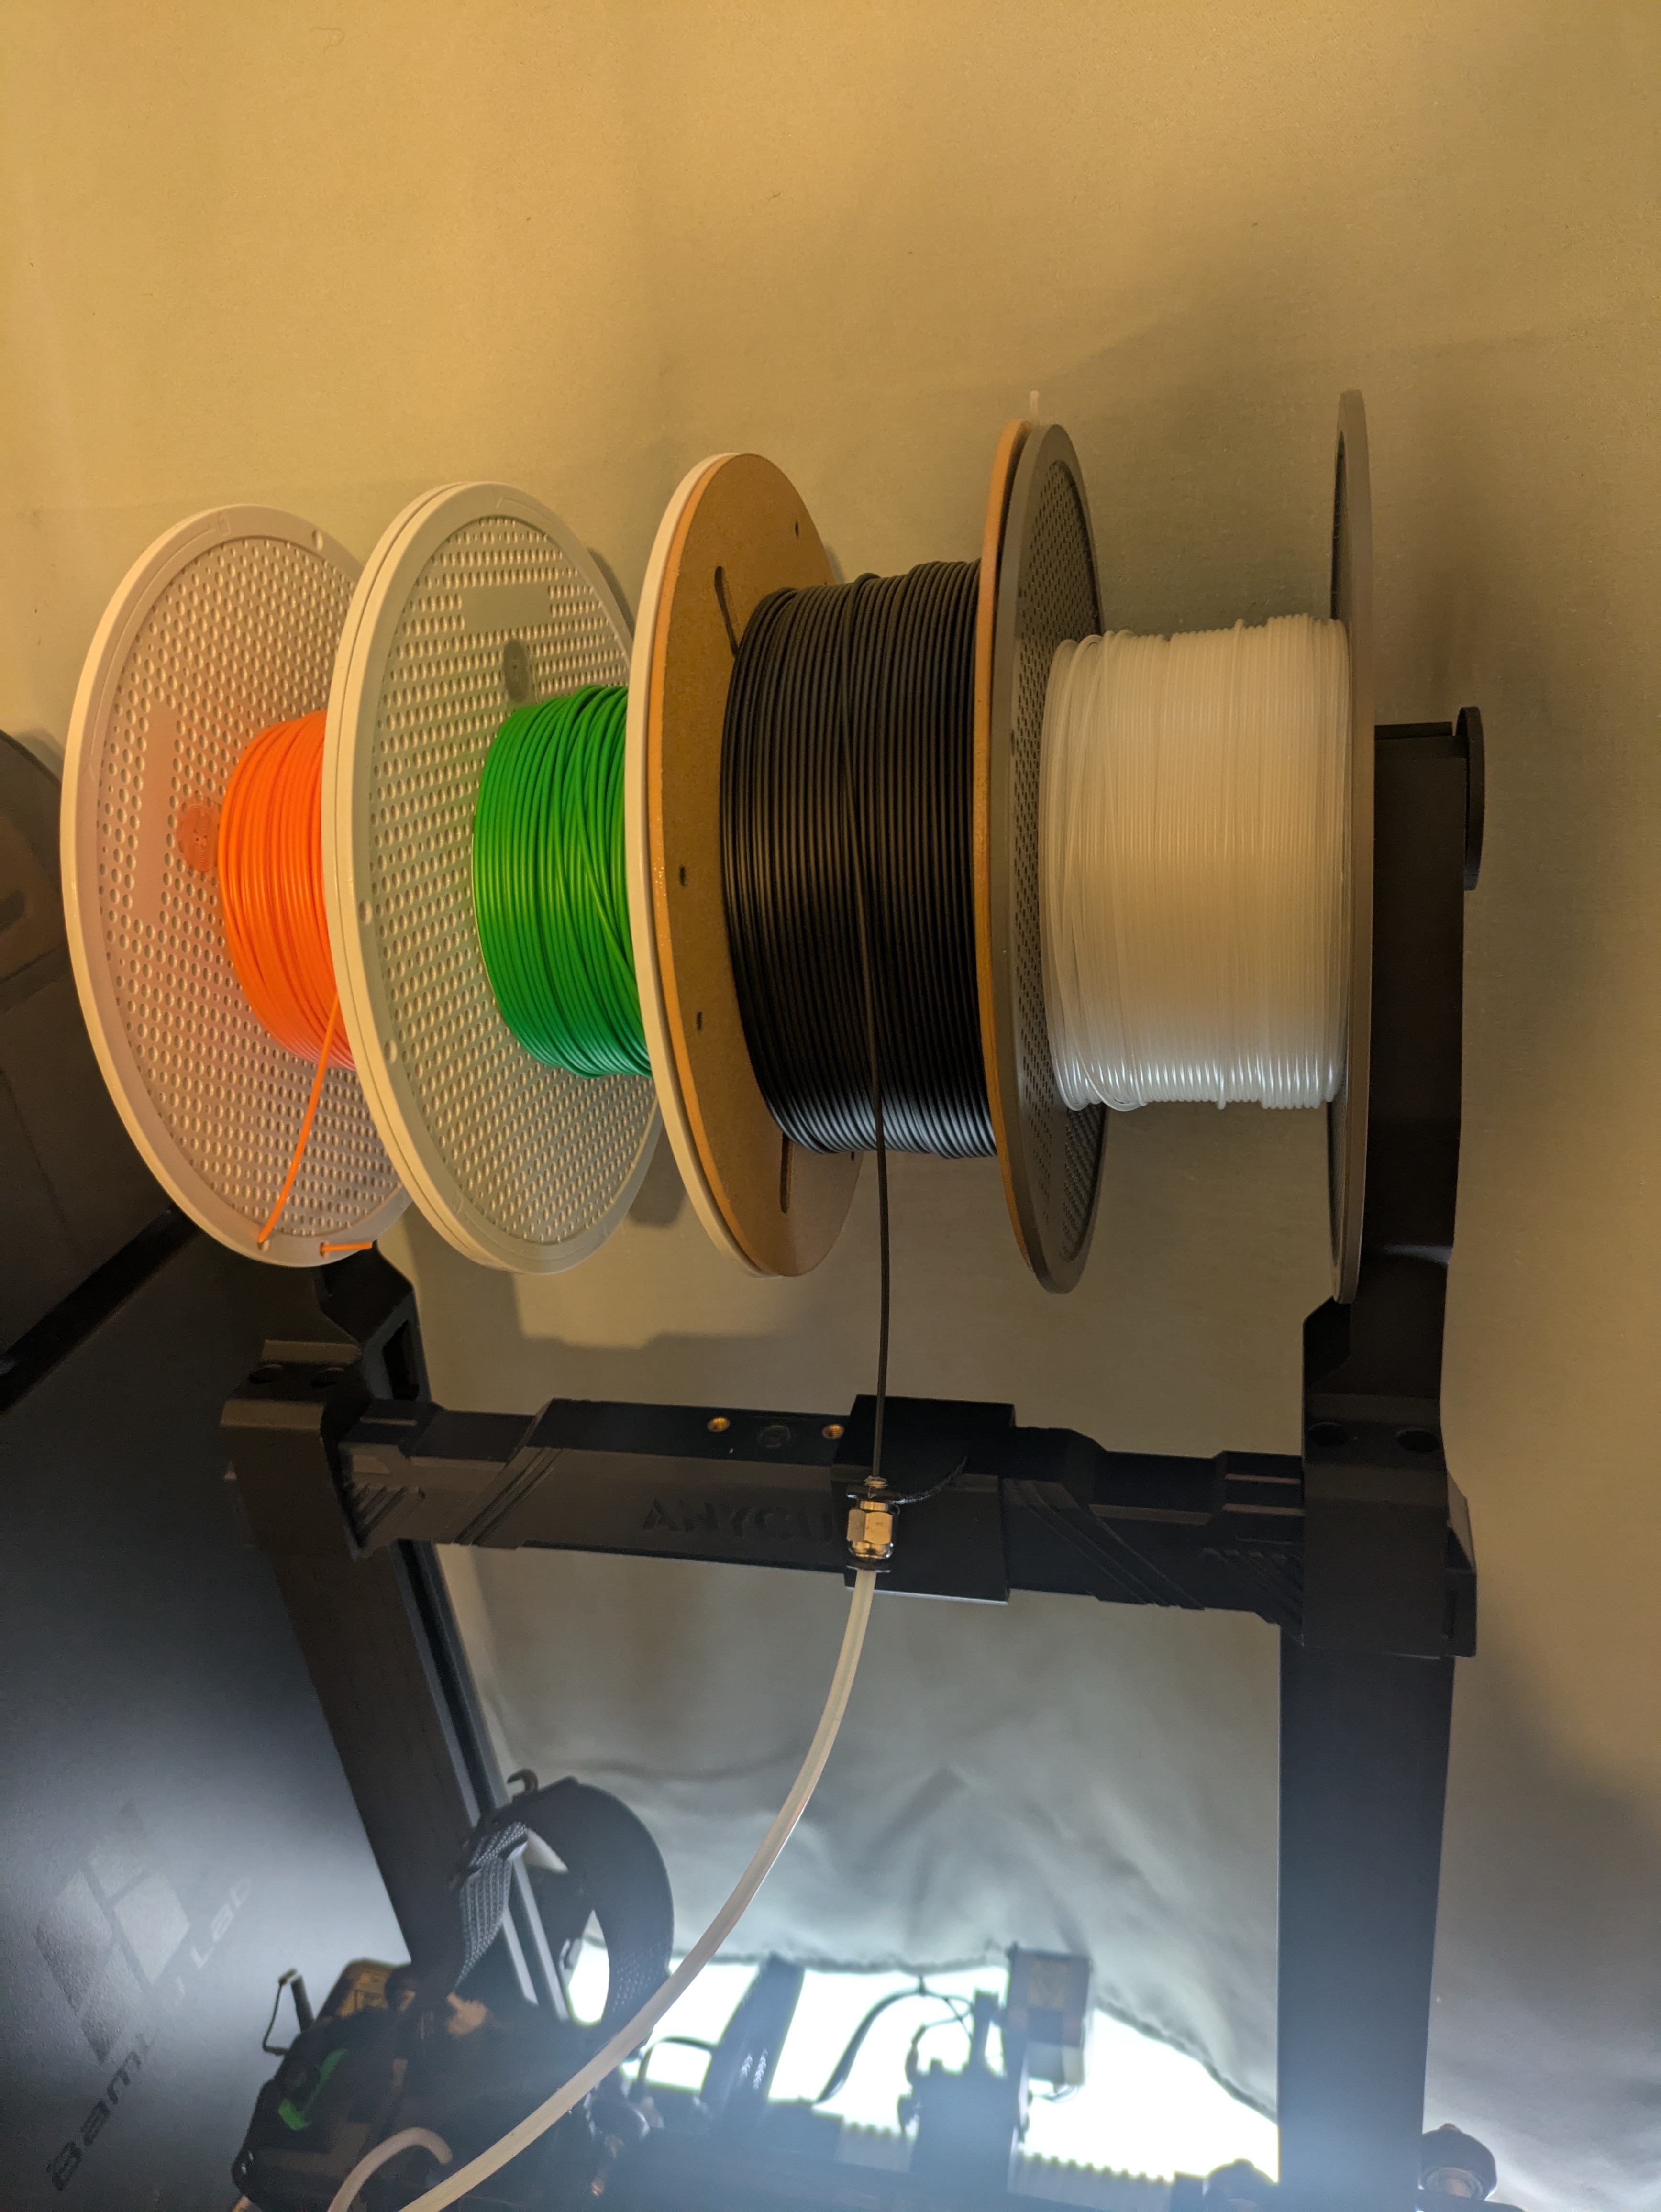
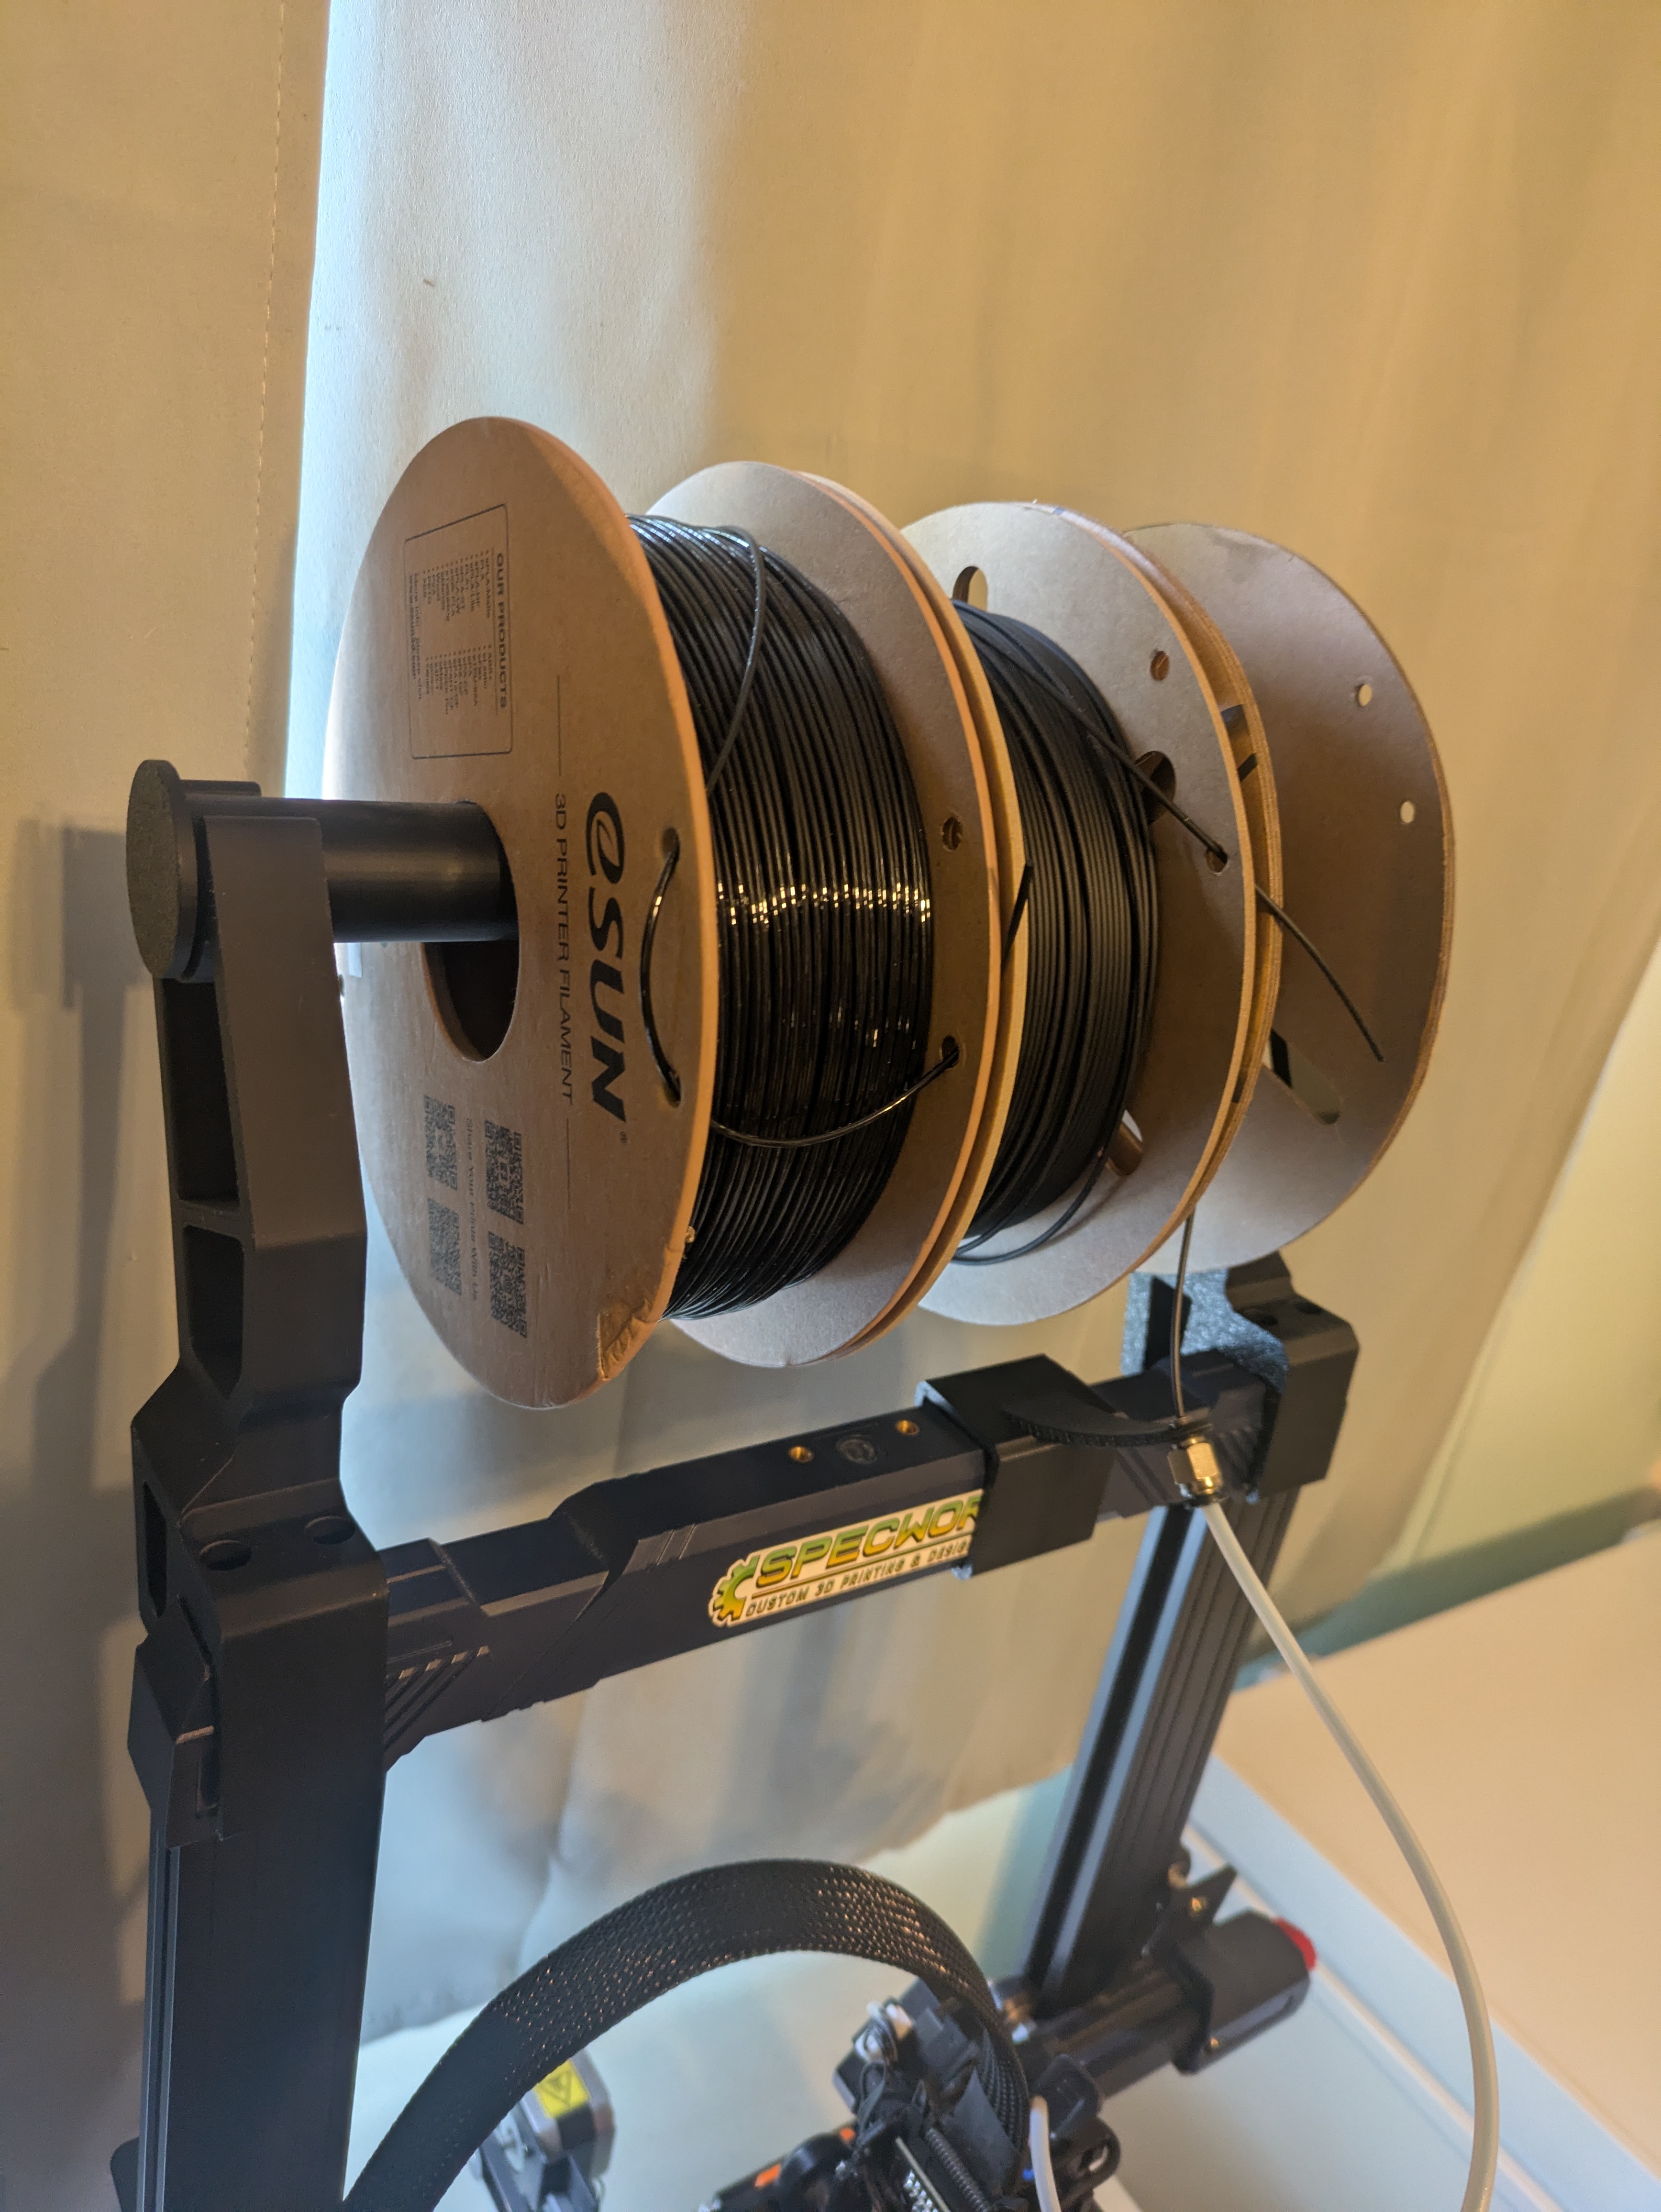
Kobra 2 Neo Top Mount Multi Spool Holder (3 Spool or 4 Spool)
- Arrives in 2 to 7 business days Printed in Auckland. $10 shipping, free over $75
- 14-day faulty refund If it arrives broken or misprinted, we reprint or refund it
- Secure checkout Card payments handled by Stripe
- Material
- High-Detail Resin (8K)
- Colour
- Grey
- Weight
- ~37 g
- Print time
- ~2 h
- Express shipping
- $20
More information
This is both a 3 spool and 4 spool top mounted holder, and ptfe tube holder that slides with it. You will have to get longer screws if you want to screw it down to be more stable. I have been using mine without, but would not recommend. If you decide to try this for the max and pro please let me know if it works and ill update the description, maybe mirror the left side for the right for the dual z axis. Thanks to these authors, who put in the work to measure the things and save me some time measuring myself. https://www.printables.com/model/850189-z-axis-support-for-anycubic-kobra-2-neo https://www.printables.com/model/1135204-anycubic-kobra-2-neo-filament-guide
Design and description by SpecWorkz , licensed CC-BY-SA.
More 3D printed Anycubic printer accessoriesMore 3D printed spool holders
Frequently asked
How long does shipping take?
Kobra 2 Neo Top Mount Multi Spool Holder (3 Spool or 4 Spool) is printed to order. Lead time is typically 1-3 business days plus 1-4 days NZ shipping. Standard NZ shipping is $10, free over $75.
What material is this printed in?
By default this is printed in High-Detail Resin (8K) at 0.025 mm layer height on an MSLA resin printer. Custom material and colour swaps are available, just leave a note at checkout.
Can I get this in a different colour?
Yes. Every product can be printed in any of the resin colours we stock, or hand-painted on request. Leave a note at checkout or email [email protected].
Do you ship outside of New Zealand?
Currently New Zealand only. Australian shipping is coming.
Who designed this?
Designed by an independent sculptor and licensed for commercial printing. The original is linked on this page.